James Stedman

I’m a PhD researcher in the School of Computing at the University of Kent, where I’m supervised by Ioanna Giorgi. I work on multilingual natural language processing, developing cognitively inspired methods for resolving ambiguity in English–⁠Japanese machine translation.

Before my PhD, I did a BSc in Computer Science at Kent and worked at Fox Robotics on reinforcement learning for autonomous navigation. I also speak Japanese (JLPT N2).

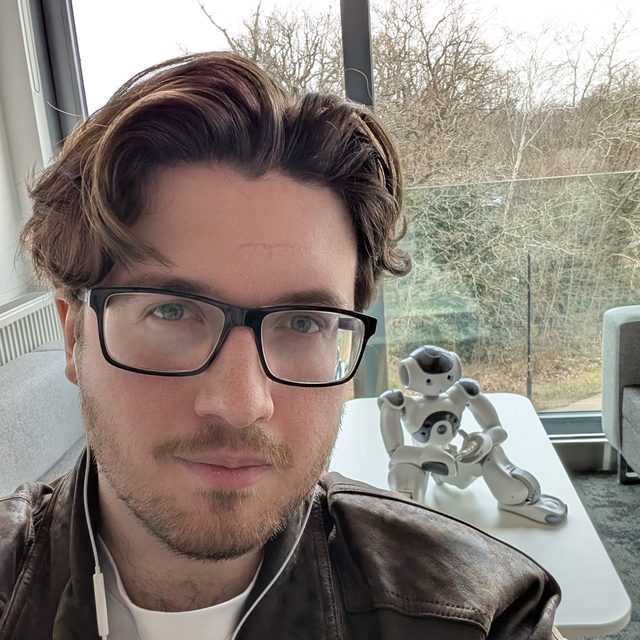
James Stedman, with a small humanoid robot on the table behind him

Research

I’m interested in how context resolves ambiguity in translation, from where things are in a scene (the paper below) to who is talking to whom. My work combines multimodal context from robotic perception with computational models of theory of mind to resolve pragmatic ambiguity, such as the level of politeness that an English sentence leaves unsaid but a Japanese translation has to choose. Right now I’m building an English–⁠Japanese politeness dataset and a theory-of-mind model that infers the relationship between speaker and listener, and connecting the model to a Pepper robot to test whether what the robot sees and hears improves translation.

Two readings of “every apple is in a bowl” In one reading each apple is in some bowl, so the apples can be spread across bowls; in the other, a single bowl holds every apple.

A Cognitive Approach to Resolving Semantic Ambiguity in Quantifier Interpretation for Machine Translation

James Stedman, Ioanna Giorgi, Giovanni Masala
ICICR, 2026
abstract / bibtex

Learning the task from a small set of examples, a cognitive architecture interprets ambiguous quantifier scope with 85% accuracy and translates the sentences into Japanese with 63% accuracy. The four open-weight LLMs we tested reach at most 72% and 45%, mostly defaulting to a single reading.